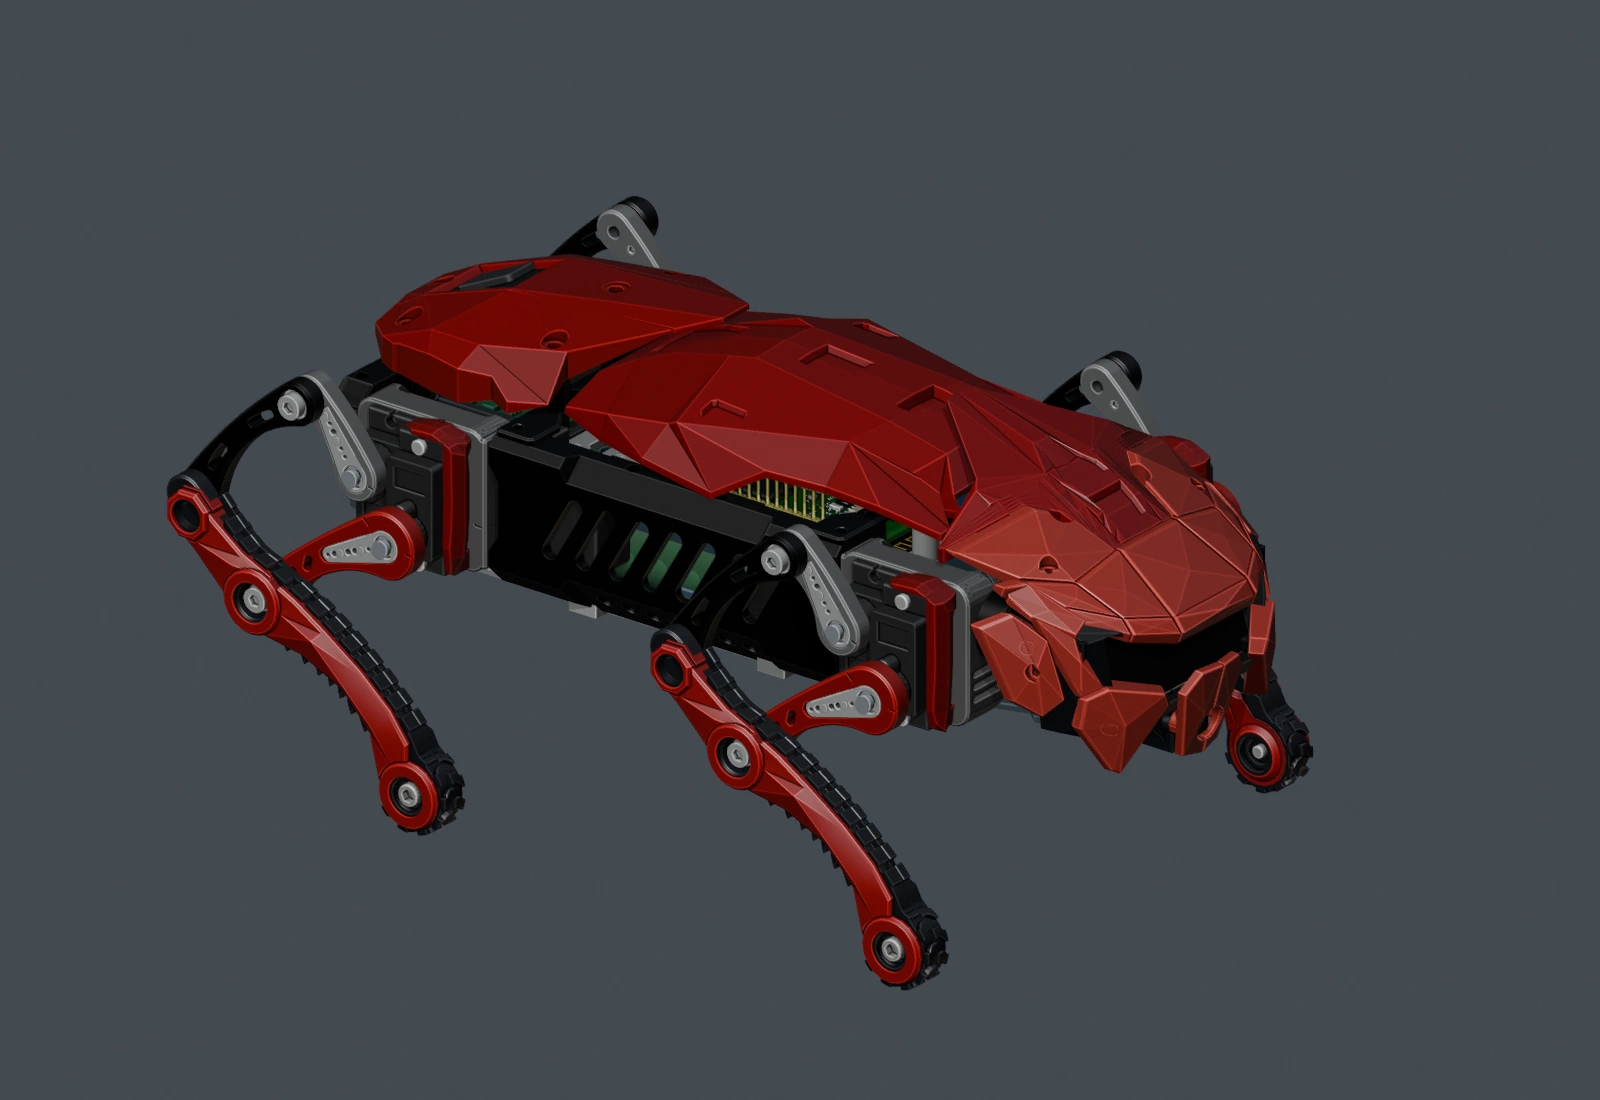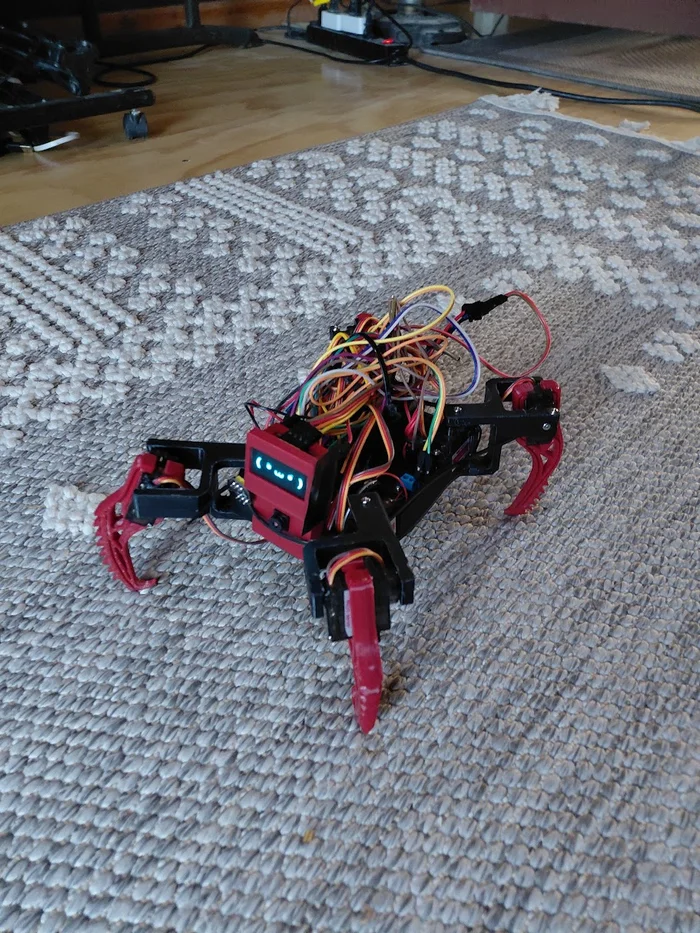
Ainekio V1 and V2: Eight Servos Versus Twelve
Eight versus twelve servos: motion generation, measured feedback, processors and the current 650 g V2 battery/charger assembly, alongside dated motion ranges.
Understanding AinekioAinekio documentation
Category: physical robot · Browse the complete library
4 articles
References first, then journal entries.
Eight versus twelve servos: motion generation, measured feedback, processors and the current 650 g V2 battery/charger assembly, alongside dated motion ranges.
Understanding AinekioCurrent V2 hardware: 650 g assembly, 2S battery and USB-C charger, compact linkage geometry, feedback servos, training stand and dated physical trials.
Chassis, shell & powerThe eight-servo robot, its documented components and wiring, enclosure history, and the move to V2.
Original eight-servo robotMotion, camera, audio, provisioning, storage, and recovery on the current eight-servo controller.
Original eight-servo robotNo articles match these filters. Try another topic, version, or search phrase.